PRESSWOOD PALLET AUTOMATION | AUTOG
The press-out scenario: heat and resin-gas exposure
A Molded wood pallet unloading robot removes the operator from the hot, fume-prone press area after thermoset resin molding. AutoG uses vacuum take-out, transfer, and stacking to connect molded wood pallet production with a safer, more consistent offloading step.
Why manual unloading leaves a gap
The conventional solution is manual pallet unloading at each press, followed by secondary carrying and stacking. On a line using two presses, this can mean about two take-out workers, while the freshly demolded pallet may be around 80°C. Waiting for the pallet to cool can add press-side delay; asking people to handle it immediately keeps them in the hazardous work zone. Manual handling also makes a fully automatic pallet production line difficult to sustain through long operating periods. The problem is therefore the complete offloading sequence—not simply lifting one pallet.
Why AutoG fits the molded pallet process
AutoG is adapted to the presswood pallet production line as an automatic pallet take-out robot, rather than as a replacement for the hydraulic press itself. After the mold opens, its six-axis articulated robot arm enters the mold area, engages the pallet with a vacuum suction gripper, and transfers it to the stacking position. One arm can serve two molded pallet hydraulic presses in an alternating sequence: it waits during pressing, unloads the completed pallet, stacks it, and then changes to the other press. The documented application range includes 1250–1600 ton presses, while the final layout and cycle coordination should be confirmed for the specific line.
Structure, evidence, and the final result
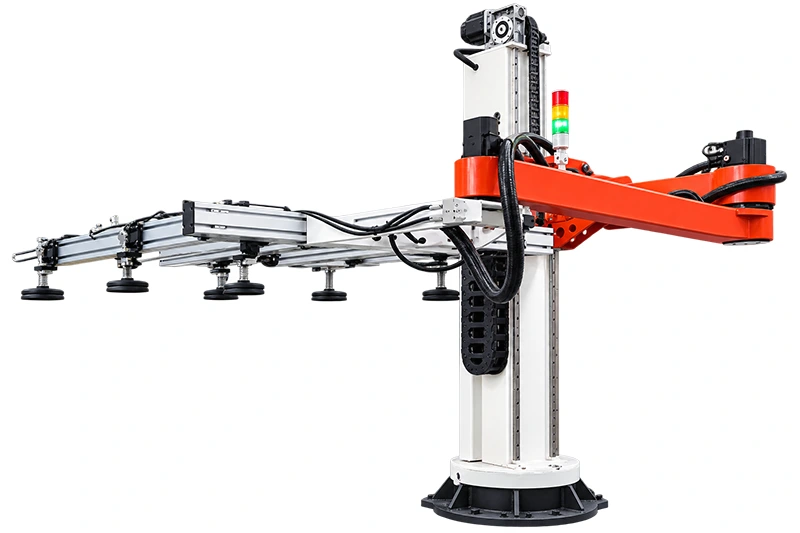
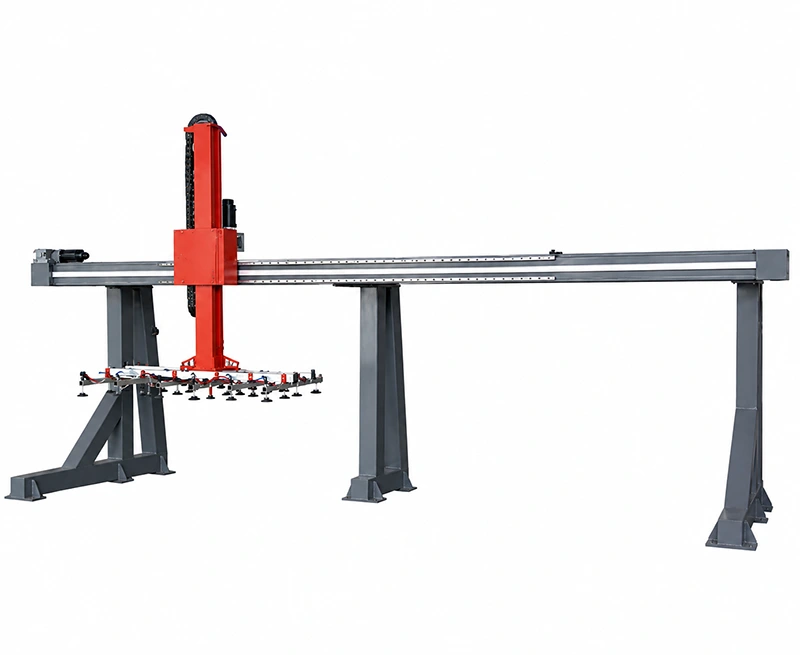
The product evidence is visible in the selected AutoG assets. The industrial photograph shows a long articulated arm, multi-cup suction head, cable chain, and stack light—the physical elements used for controlled vacuum pallet transfer. The second image is a product rendering of a long-span gantry vacuum lifter with a multi-cup gripper; it illustrates the movement envelope and gripper concept, not a substitute for a project-specific drawing. Application information confirms automatic take-out, transfer, and stacking, with safe handling of pallets at about 80°C. In the finished sequence, the operator no longer needs to stand at every press opening: AutoG moves the hot pallet directly toward stacking, supports dual-press tending, and helps upgrade a semi-automatic line to full-auto offloading. The result is a combined safety and health benefit, with fewer manual touchpoints and a clearer route to continuous production—subject to final engineering validation of the press, gripper, controls, and operating conditions.
- Confirm the press model, take-out position, pallet temperature, and stacking layout before final integration.
- Confirm the required vacuum gripper arrangement and handling envelope for the molded pallet format.
- Confirm the control and safety interfaces between AutoG, the hydraulic presses, and the line PLC.
- Validate the dual-press sequence, maintenance access, and operating conditions with EMP engineering.


