EMP | AutoG robotic offloading for presswood pallet lines
Why press-side offloading becomes a production issue
AutoG is the press-side robotic offloading component for molded wood pallet production lines, moving hot-pressed pallets from demolding to stacking.
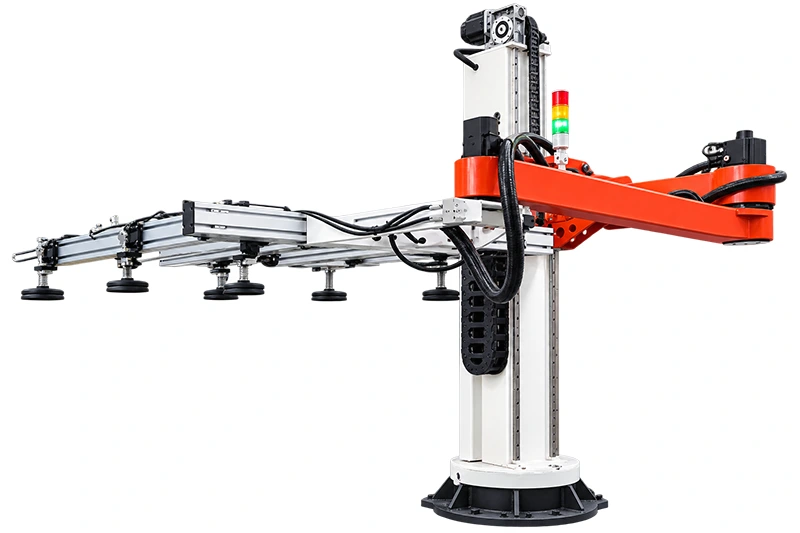
Designed for dual-press tending
AutoG is positioned beside the hydraulic press, using vacuum suction picking and six-axis movement to transfer pallets from the press to the stacking position; one arm can serve two presses when the line layout and controls are confirmed.
Source-backed operating boundaries
The supplied production materials identify approximately 80°C pallet handling, 1250–1600 ton press compatibility and a related 4–5 minute press cycle. Load, reach, precision, vacuum specification and installation dimensions require engineering confirmation.
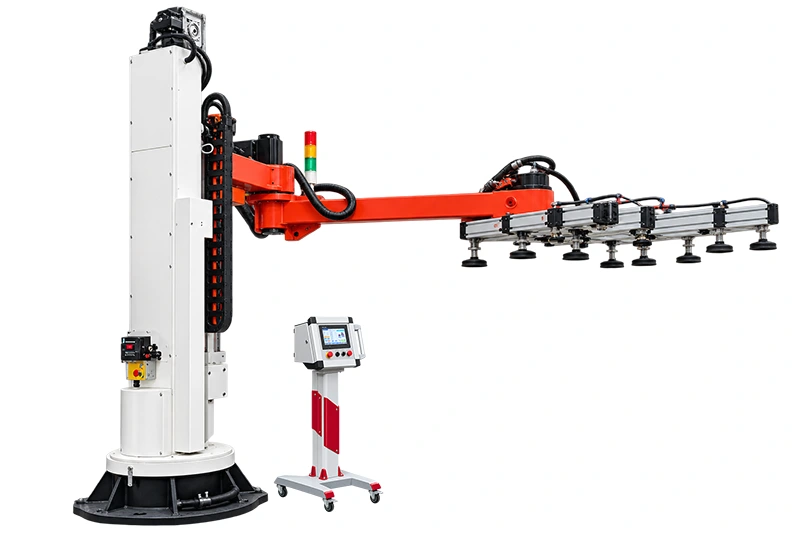
What to confirm before integration
The final cell design should confirm press interface, gripper arrangement, robot reach, safety controls, cycle timing and stacking position against the actual line layout.
- Source route and product profile are fixed to EMP AutoG.
- Image paths are bound to the AutoG designer gallery.
- Unpublished engineering parameters remain open for confirmation.
- The renderer receives structured fields only; it does not choose layout or media order.


