Pallet demolding robot for presswood pallet production lines
The press cycle is only as fast as the take-out step
A Pallet demolding robot removes molded wood pallets as soon as the press opens, instead of making the press wait for manual handling. AutoG combines approximately 80°C direct take-out, vacuum suction transfer, and press open/close signal coordination through the line PLC to support a steadier presswood pallet production line and improved OEE potential.
Why manual pallet unloading holds back the line
Manual take-out does not follow the press rhythm precisely. If the operator is not ready, the hydraulic press waits after demolding; if the operator works ahead, the task still requires people inside a high-temperature, high-risk press area. MDI adhesive is also used in some molded pallet processes, so reducing routine personnel exposure at the hot press pallet unloading point is an important automation objective. After manual removal, secondary transfer and stacking add another delay and make continuous operation more difficult.
Why AutoG fits press-side demolding
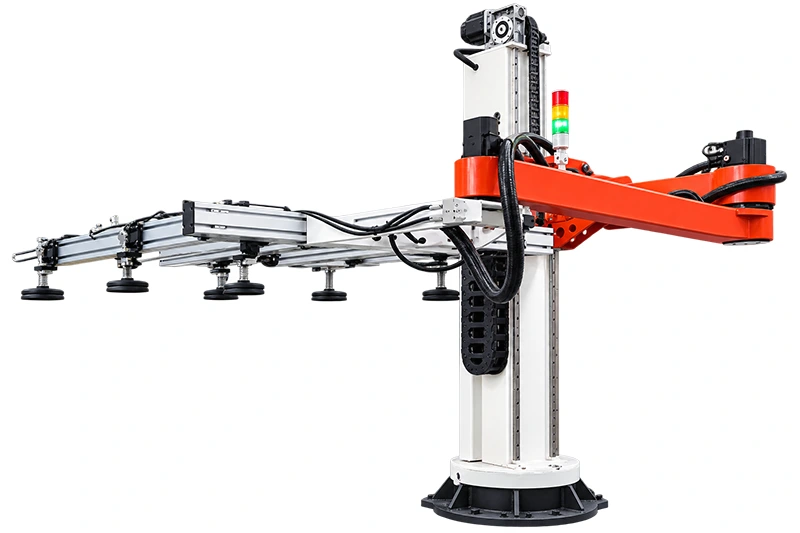
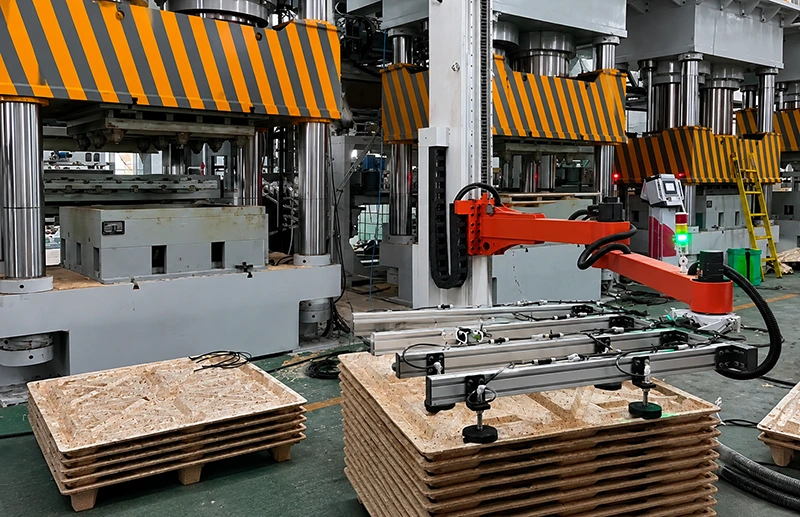
AutoG is designed as a dedicated automatic take-out robot for molded wood pallet lines. It works at the press outfeed rather than replacing the hydraulic press: after the mold opens, its six-axis articulated robot arm uses a vacuum suction gripper to pick up the finished pallet, transfer it, and place it at the stacking position. In a dual-press arrangement, one arm can tend two presses in alternation. With the press open/close signal coordinated through the line PLC, the robot can wait during pressing and execute the take-out sequence when the press is ready.
Structure, evidence, and the production result
The product evidence shows the practical configuration: the AutoG unit has a long articulated arm, cable management, a stack light, and a multi-cup vacuum end effector. A separate factory image shows the robotic arm working beside a hydraulic press with stacked panels, matching the press-tending and automatic stacking application. Confirmed reference points include approximately 80°C pallet handling, six-axis motion for positioning and orientation, vacuum suction transfer, and one-arm/two-press service. The result is a shorter handoff between mold opening and stacking, less dependence on manual cooling and carrying, reduced press waiting, and a stronger basis for improving single-line OEE. Final load, reach, vacuum, installation, and PLC interface details should be confirmed in the engineering proposal.
- Use “Pallet demolding robot” in the title, SEO title, slug, H1, first-screen summary, and both image alts.
- Keep the article focused on press-side take-out and stacking for molded wood pallet production lines.
- Use only confirmed facts: 4–5 minute pressing cycle, approximately 80°C pallet handling, six-axis articulated arm, vacuum suction gripper, and one arm serving two presses.
- State reduced press waiting and improved OEE potential without inventing throughput, ROI, load, reach, precision, or PLC model figures.


