AutoG | Robotic offloading for presswood pallet production lines
Customer scenario: labor cost multiplies across a multi-press layout
Automatic palletizing robot for pallet line: AutoG helps molded wood pallet manufacturers address the labor cost that grows with every additional press. One robot can alternate between two pallet presses, remove hot pallets with a vacuum gripper, and transfer them to the stacking position for a practical presswood pallet production line upgrade.
Why manual press tending becomes the bottleneck
The conventional process places people close to a high-force press during take-out. A newly demolded pallet can be about 80°C, and MDI adhesive used in molded pallet production may create gas during hot pressing. Manual unloading therefore combines repetitive handling, hot pallet exposure, and a second transfer or stacking step. It is also difficult to maintain the same manual rhythm for continuous production, especially when a semi-auto to full-auto line upgrade is being considered.
Product fit: one arm, two presses, direct vacuum transfer
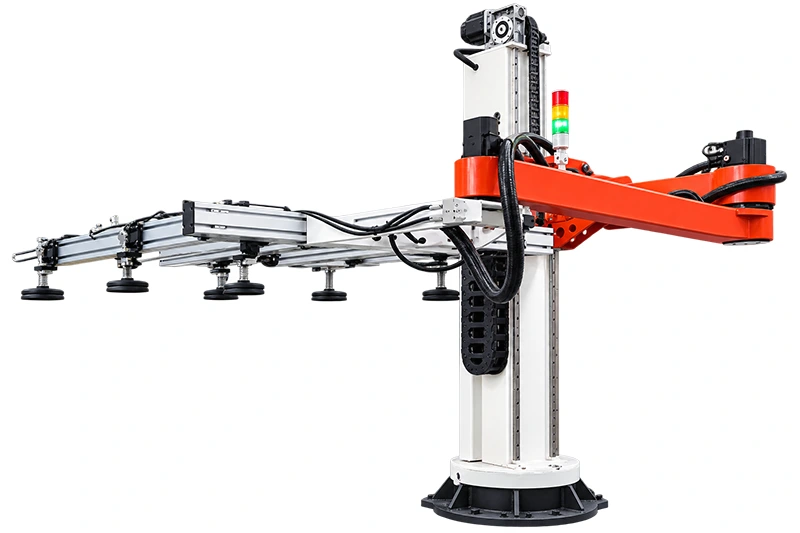
AutoG is designed for the press-side boundary of a molded wood pallet manufacturing line. After the press opens, its six-axis articulated robot arm uses a vacuum suction gripper to pick the finished pallet, adjust its orientation through coordinated motion, and move it from the press to the stacking position. The key configuration is one arm two presses: one AutoG alternates between two pallet presses, waiting during pressing and serving the press that has completed its cycle. The source brief identifies a 4–5 minute pressing cycle with MDI adhesive as a press-side reference, not a guaranteed line output.
Evidence and result: higher capital efficiency at the unloading end
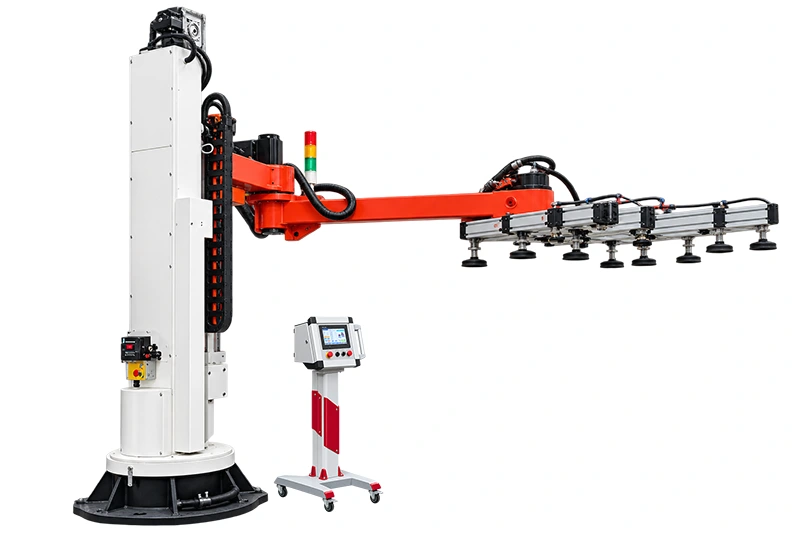
The selected AutoG images provide visible evidence for the equipment layout. The product view shows a floor-mounted industrial vacuum handling robot with a long articulated arm, multi-suction head, cable chain, and stack light. The second view shows the vacuum lifting arm together with a multi-cup sheet-handling beam and mobile control pedestal. These visible elements support a practical automatic stacking and palletizing arrangement, while final load, reach, precision, vacuum specification, installation dimensions, and control-interface details should be confirmed for the customer’s presses. In the resulting presswood pallet production line, one robot is configured to serve two presses, replacing the two press-side take-out operators in the stated comparison and moving the process toward safer, more consistent automatic offloading. Contact EMP to review the press layout, pallet format, and integration boundary.
- Customer scenario: a molded wood pallet base with multiple hydraulic presses needs to reduce labor added at each press
- Old approach: one operator removes hot pallets at each press, then handles transfer and stacking separately
- Product fit: AutoG is an automatic pallet take-out robot with one-arm-two-press tending and vacuum pickup
- Evidence and result: indexed AutoG images show the articulated arm, suction head, cable chain, control pedestal, and press-side automation


