AUTOG | AUTOMATIC PALLET TAKE-OUT ROBOT
When a New Pallet Line Starts Without Press-Molding Experience
Pallet demolding robot for molded wood pallet production lines: how an integrated press, take-out, stacking, and PLC package reduces the risk of building a hot-press process from zero.
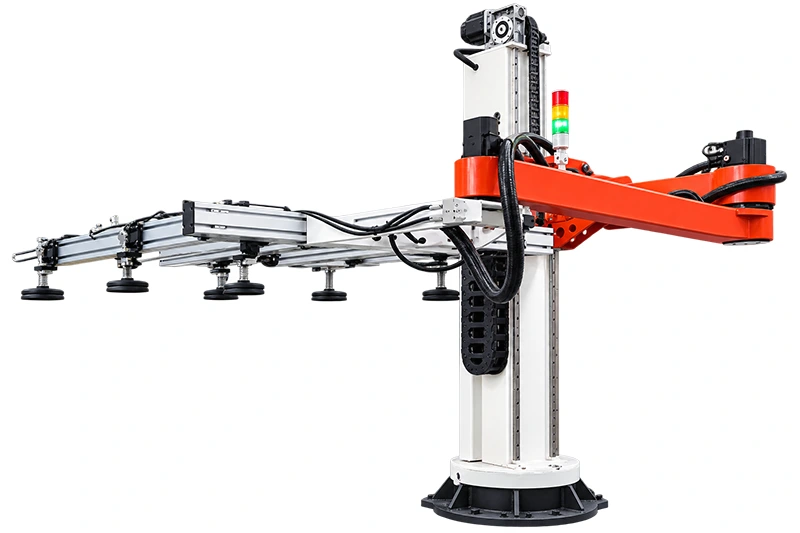
Why Manual Hot-Press Unloading Becomes the Bottleneck
The legacy approach is simple to describe but difficult to scale. Operators remove each molded pallet beside the press, move it again, and stack it manually. With two presses, the line may need about two take-out workers, while the newly demolded pallet can be around 80°C. MDI adhesive used in the hot-press process can also generate gases during heating, so keeping people at the press discharge area is an operational concern. Manual handling interrupts the transition from pressing to stacking and makes a semi-auto to full-auto line upgrade harder to control.
Why AutoG Fits a Turnkey Press-to-Stacking Process
AutoG is designed as a pallet demolding robot and automatic take-out robot for the press discharge end, not as a standalone hydraulic press or a generic warehouse palletizing robot. EMP supplies the press, AutoG take-out, stacking, and PLC integration as one turnkey line package. The fit is therefore practical for a customer starting from zero: the robot is planned around the press opening, the pallet transfer path, the stacking position, and the control sequence instead of being added after the line has already been built. One AutoG can serve two molded wood pallet hydraulic presses in an alternating cycle, waiting during pressing and taking out, transferring, and stacking after the selected press opens.
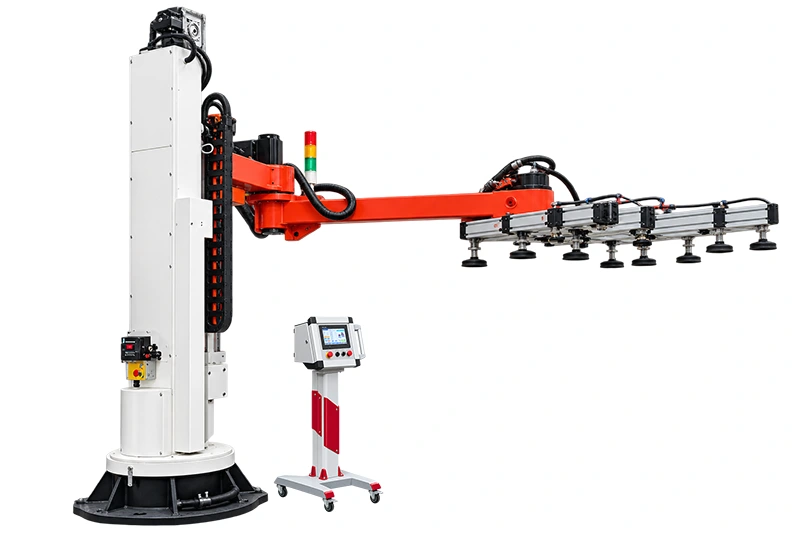
Structure, Operating Evidence, and What the Images Show
The documented configuration combines a six-axis articulated robot arm with a vacuum suction gripper. The axes support up, down, left, right, forward, and backward movement plus turning or rotation for pallet take-out and stacking orientation. The confirmed application range includes 1250–1600 ton molded wood pallet presses, and the equipment description states that it can safely handle pallets at about 80°C. Related source material cites a 4–5 minute pressing cycle with MDI adhesive; this is a press-side reference, not a guaranteed line output. The two images show the transfer-station layout and visible guide, cable-chain, gripper, and control elements. They support the application logic, but do not establish undisclosed load, reach, precision, vacuum, power, or PLC specifications.
- Pallet demolding robot is the primary phrase for the article title, SEO title, slug, H1, first-screen summary, and image ALT text.
- The article follows the required logic: customer and scenario, legacy-process problems, product fit, confirmed structure and evidence, and final operational result.
- Only confirmed AutoG facts are used; unpublished load, reach, accuracy, vacuum, power, PLC model, and installation dimensions are not presented as specifications.
- The article is written entirely in English for an industrial B2B audience and includes a contact CTA in the fixed rendered body.


