AUTOG | PRESSWOOD PALLET AUTOMATION
The customer scenario: hot press unloading across every shift
Six-axis pallet handling robot automation addresses a specific bottleneck in molded wood pallet manufacturing: removing hot pallets from the press when hiring for dirty, hazardous, difficult take-out work is becoming harder and night-shift staffing is unstable. AutoG is an automatic pallet take-out robot designed for the press discharge and stacking stage, helping a plant move from manual unloading toward a more continuous 24/7 pallet production automation model.
Why the old take-out method becomes the constraint
Manual hydraulic press pallet take-out creates three practical weaknesses. First, people must repeatedly work beside a high-force press and handle a hot product. Second, manual removal is followed by secondary transfer and stacking, adding walking, lifting and coordination to the cycle. Third, the line depends on finding stable operators for every shift. Waiting for a pallet to cool can also add press-side delay, while asking people to work faster increases exposure and inconsistency. This is why a semi-auto to full-auto line upgrade should examine the offloading stage, not only the press itself.
Why AutoG matches the press-side application
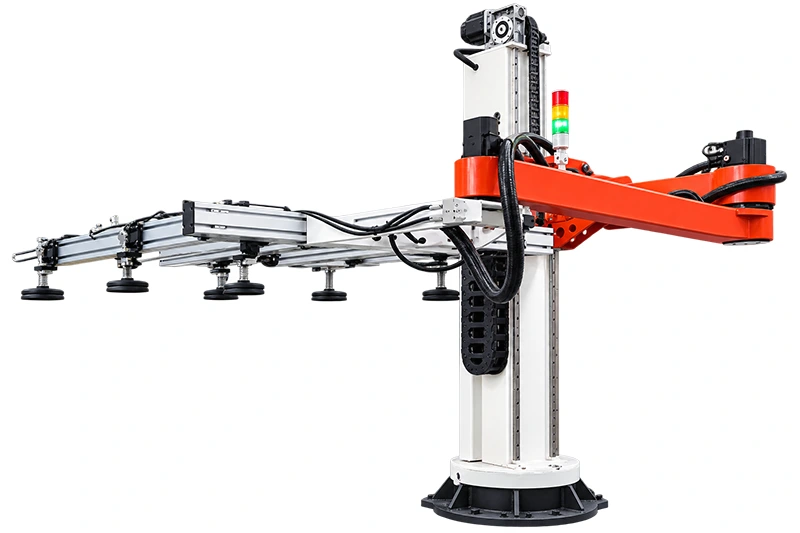
AutoG fits this application because it is a dedicated robotic offloading component for the molded pallet press, not a replacement for the hydraulic press and not a general warehouse palletizer. After the press opens, the six-axis articulated robot arm enters the mold area, uses a vacuum suction gripper to pick the pallet, transfers it to the stacking position and then returns to serve the next task. One arm can alternate between two molded pallet hydraulic presses: it waits during pressing, takes out the finished pallet from press A or B, and uses its six-axis motion to adjust the approach and placement orientation. The result is a one-arm-two-press layout that matches an alternating press-tending workflow.
Structure and evidence for a controlled automation decision
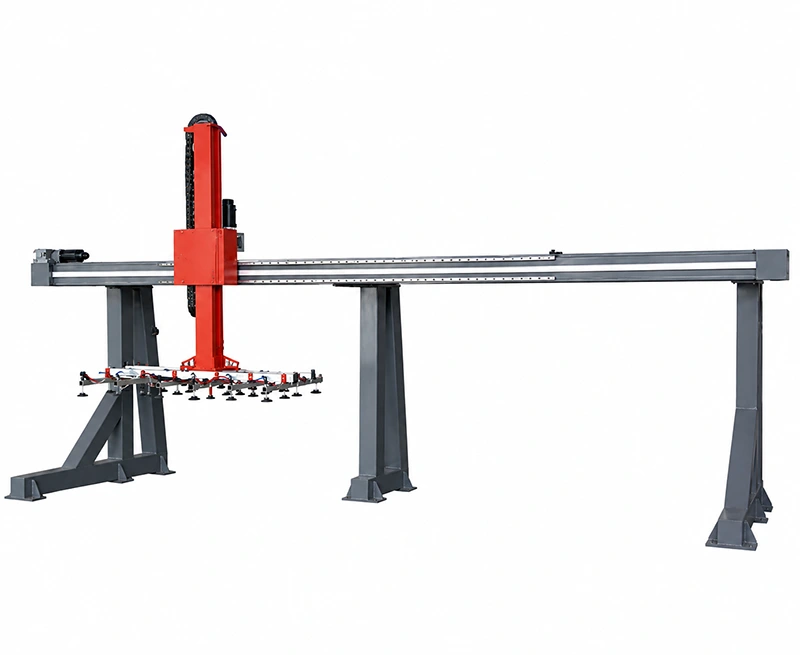
The selected product image shows the visible equipment logic: a long articulated arm, suction cups, cable chain and stack light. The second image is a product rendering showing a long-span gantry vacuum lifter, multi-cup gripper and guided transfer structure; it is used as a layout explanation, not as proof of an undisclosed load, reach or accuracy specification. Confirmed application facts are more important than unverified numbers: AutoG is described as handling pallets at approximately 80°C, serving two presses, and performing automatic take-out, transfer and stacking. The 4–5 minute figure in the source material belongs to the press-side cycle using MDI adhesive and should be confirmed for each line design. Robot payload, reach, precision, vacuum-system specification, power and installation dimensions must be checked in the technical proposal.
- Use the exact phrase Six-axis pallet handling robot in the SEO title, slug, H1, opening summary, and image ALT context.
- Keep the article fully English and follow the sequence: customer scenario, old method problems, product fit, structure and evidence, final operating result.
- Use only confirmed AutoG facts: one robot serving two presses, six-axis articulated motion, vacuum suction transfer, approximately 80°C pallet handling, and 24/7 operation as a source-described capability.
- Use the selected AutoG designer-gallery images with their indexed English ALT text and include a /contact/ call to action.


